
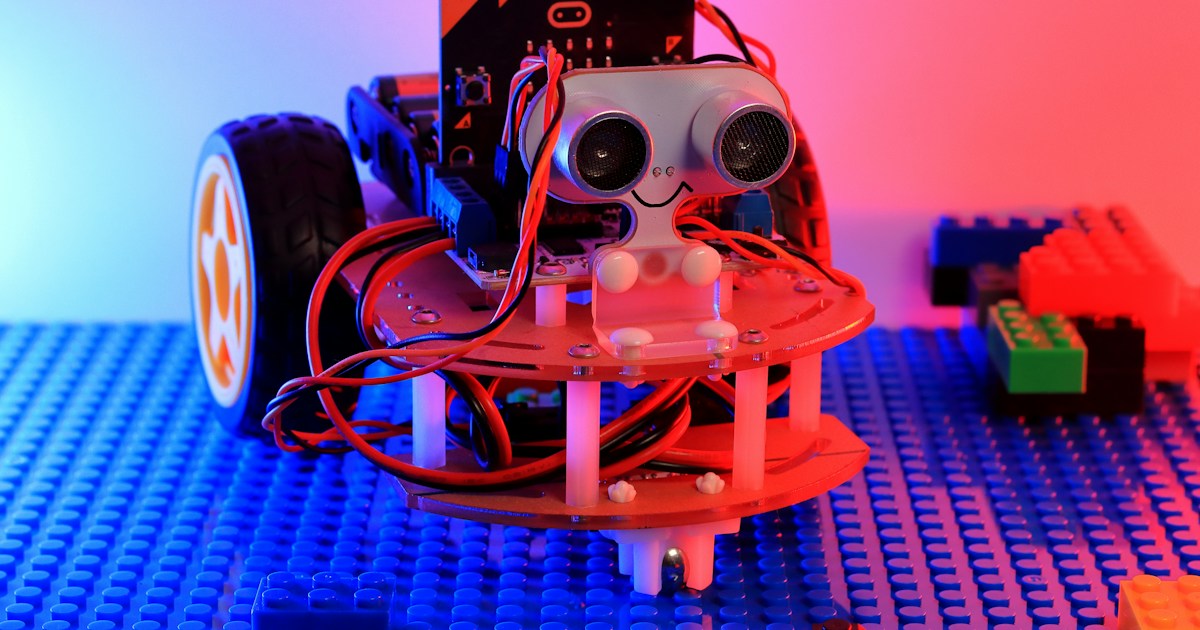
For getting started with Pico robotics, begin with a Raspberry Pico, a dual motor driver, two small DC gear motors, and a simple rover chassis. Never connect motors directly to the Pico’s GPIO pins: use a driver, check voltage levels, and test one part at a time.
We’ve found that the first big breakthrough usually isn’t a robot racing across the room. It’s a motor turning the right way, followed by a sensor reading that changes when you move your hand. Those small wins teach you the essentials of robot building: wiring, coding, mechanics, and debugging.
The Pico’s RP2040 microcontroller runs at up to 133 MHz, giving it plenty of capability for beginner projects such as line followers and obstacle-avoiding rovers. Start with MicroPython and a basic two-wheel robot; add wireless control or more sensors after the wheels behave. 🔧
Key Takeaways
- Start small: A two-wheel rover is a practical first Pico robotics project.
- Use a motor driver: It protects the Pico from motor power demands and lets you control direction and speed.
- Respect voltage levels: Pico GPIO uses 3.3 V logic; check sensor outputs before wiring them.
- Test each subsystem separately: Confirm the Pico, motors, and sensors work before combining them.
- Choose beginner-friendly tools: MicroPython and Thony make it easy to write, run, and debug your first robot program.
- Add features gradually: Get basic movement working before adding obstacle avoidance, line following, or Pico W wireless control.
Table of Contents
- ⚡️ Quick Tips and Facts About Pico Robotics
- 🤖 What Is Pico Robotics?
- How the Raspberry Pico Fits Into a Robot
- Raspberry Pico vs. Pico W: Which Should You Choose?
- MicroPython, CircuitPython, and C/C++ at a Glance
- 📜 The Evolution of Raspberry Pico Robotics
- 🧭 Plan Your First Pico Robot
- Choose a Beginner-Friendly Robot Project
- Set a Realistic Scope and Build Budget
- 🔧 Essential Pico Robotics Supplies and Tools
- Microcontroller Boards, Cables, and Breadboards
- Motors, Wheels, Chassis, and Mechanical Parts
- Motor Drivers, Batteries, and Power Supplies
- Sensors for Obstacle Avoidance and Line Following
- Hand Tools and Safety Gear
- 🛠️ Step 1: Set Up Your Raspberry Pico for Robotics
- Install Thony and Connect Your Pico
- Flash MicroPython or CircuitPython Firmware
- Run a First Test Program
- ⚙️ Step 2: Learn Motor Control and Choose a Driver
- How DC Motors, Servos, and Steppers Differ
- Using an L298N Motor Driver Board
- Alternatives to the L298N: TB6612FNG and DRV883
- Control Speed with PWM and Direction Pins
- 🧩 Step 3: Design and Build the Robot Chassis
- Choose a Two-Wheel or Four-Wheel Drive Layout
- Mount Motors, Wheels, and the Caster
- Position the Pico, Sensors, and Battery
- 🔌 Step 4: Wire the Pico Robot Electronics Safely
- Connect the Pico to a Motor Driver
- Wire Ultrasonic, Infrared, and Line Sensors
- Plan Power, Ground, and Voltage Levels
- Check Your Wiring Before Switching On
- 💾 Step 5: Program Your Pico Robot
- Write a MicroPython Motor-Control Program
- Read Sensors and Add Obstacle Avoidance
- Try CircuitPython Libraries and C/C++
- Organize Code with Functions and State Machines
- 🚀 Step 6: Install Drivers and Test Your Robotics Setup
- Check USB, Serial, and Thony Connections
- Test Motors and Sensors One at a Time
- Calibrate Movement and Sensor Readings
- 🎉 Step 7: Bring Your Pico Robot to Life with First Projects
- Build a Remote-Controled Pico Robot
- Make a Line-Following Robot
- Create an Ultrasonic Obstacle-Avoiding Robot
- Add Wi-Fi Control with a Raspberry Pico W
- 🔋 Powering and Maintaining Your Pico Robot
- Choose Batteries and Estimate Runtime
- Avoid Brownouts, Overheating, and Electrical Damage
- Inspect, Store, and Maintain Your Robot
- 🔍 Troubleshoot Common Pico Robotics Problems
- The Pico Is Not Recognized by Your Computer
- Motors Do Not Turn or Run in the Wrong Direction
- The Robot Resets When the Motors Start
- Sensors Give Unreliable Readings
- Fix MicroPython Errors and Pin Conflicts
- 💡 Advanced Raspberry Pico Robotics Tips
- Use Interrupts, Encoders, and Closed-Loop Control
- Add Bluetooth, Wi-Fi, or Web-Based Controls
- Design a Custom PCB or 3D-Printed Chassis
- Improve Robot Reliability and Code Performance
- 🌐 Pico Robotics Communities and Learning Resources
- Find Help in Raspberry Pi and MicroPython Communities
- Choose a Learning Path for Your Next Project
- 🏁 Conclusion: Start Building with Pico Robotics
- 🔗 Recommended Links
- ❓ FAQ: Getting Started with Pico Robotics
- Can a Raspberry Pico control motors directly?
- Is the Raspberry Pico suitable for beginners?
- Should I use MicroPython or CircuitPython for robotics?
- Can I build a robot with a Pico W?
- What motor driver works best with a Raspberry Pico?
- What do I need to build a basic Pico robot?
- Can a Pico robot run without a computer?
- 📚 Reference Links
Table of Contents
- ⚡️ Quick Tips and Facts About Pico Robotics
- 🤖 What Is Pico Robotics?
- How the Raspberry Pico Fits Into a Robot
- Raspberry Pico vs. Pico W: Which Should You Choose?
- MicroPython, CircuitPython, and C/C++ at a Glance
- 📜 The Evolution of Raspberry Pico Robotics
- 🧭 Plan Your First Pico Robot
- Choose a Beginner-Friendly Robot Project
- Set a Realistic Scope and Build Budget
- 🔧 Essential Pico Robotics Supplies and Tools
- Microcontroller Boards, Cables, and Breadboards
- Motors, Wheels, Chassis, and Mechanical Parts
- Motor Drivers, Batteries, and Power Supplies
- Sensors for Obstacle Avoidance and Line Following
- Hand Tools and Safety Gear
- 🛠️ Step 1: Set Up Your Raspberry Pico for Robotics
- Install Thony and Connect Your Pico
- Flash MicroPython or CircuitPython Firmware
- Run a First Test Program
- ⚙️ Step 2: Learn Motor Control and Choose a Driver
- How DC Motors, Servos, and Steppers Differ
- Using an L298N Motor Driver Board
- Alternatives to the L298N: TB6612FNG and DRV883
- Control Speed with PWM and Direction Pins
- 🧩 Step 3: Design and Build the Robot Chassis
- Choose a Two-Wheel or Four-Wheel Drive Layout
- Mount Motors, Wheels, and the Caster
- Position the Pico, Sensors, and Battery
- 🔌 Step 4: Wire the Pico Robot Electronics Safely
- Connect the Pico to a Motor Driver
- Wire Ultrasonic, Infrared, and Line Sensors
- Plan Power, Ground, and Voltage Levels
- Check Your Wiring Before Switching On
- 💾 Step 5: Program Your Pico Robot
- Write a MicroPython Motor-Control Program
- Read Sensors and Add Obstacle Avoidance
- Try CircuitPython Libraries and C/C++
- Organize Code with Functions and State Machines
- 🚀 Step 6: Install Drivers and Test Your Robotics Setup
- Check USB, Serial, and Thony Connections
- Test Motors and Sensors One at a Time
- Calibrate Movement and Sensor Readings
- 🎉 Step 7: Bring Your Pico Robot to Life with First Projects
- Build a Remote-Controled Pico Robot
- Make a Line-Following Robot
- Create an Ultrasonic Obstacle-Avoiding Robot
- Add Wi-Fi Control with a Raspberry Pico W
- 🔋 Powering and Maintaining Your Pico Robot
- Choose Batteries and Estimate Runtime
- Avoid Brownouts, Overheating, and Electrical Damage
- Inspect, Store, and Maintain Your Robot
- 🔍 Troubleshoot Common Pico Robotics Problems
- The Pico Is Not Recognized by Your Computer
- Motors Do Not Turn or Run in the Wrong Direction
- The Robot Resets When the Motors Start
- Sensors Give Unreliable Readings
- Fix MicroPython Errors and Pin Conflicts
- 💡 Advanced Raspberry Pico Robotics Tips
- Use Interrupts, Encoders, and Closed-Loop Control
- Add Bluetooth, Wi-Fi, or Web-Based Controls
- Design a Custom PCB or 3D-Printed Chassis
- Improve Robot Reliability and Code Performance
- 🌐 Pico Robotics Communities and Learning Resources
- Find Help in Raspberry Pi and MicroPython Communities
- Choose a Learning Path for Your Next Project
- 🏁 Conclusion: Start Building with Pico Robotics
- 🔗 Recommended Links
- ❓ FAQ: Getting Started with Pico Robotics
- Can a Raspberry Pico control motors directly?
- Is the Raspberry Pico suitable for beginners?
- Should I use MicroPython or CircuitPython for robotics?
- Can I build a robot with a Pico W?
- What motor driver works best with a Raspberry Pico?
- What do I need to build a basic Pico robot?
- Can a Pico robot run without a computer?
- 📚 Reference Links
⚡️ Quick Tips and Facts About Pico Robotics
If you’re exploring getting started with Pico robotics, our Raspberry Pico guide is a helpful companion. The short version: a Pico can read sensors and control a robot’s behavior, but it cannot safely power motors directly. That calls for a motor driver, separate motor power, and a little patience with wiring.
| Quick fact | What it means for your robot |
|---|---|
| Raspberry Pico uses the RP2040 microcontroller | It runs embedded programs directly rather than booting a desktop-style operating system. |
| Pico GPIO uses 3.3 V logic | Treat 5 V sensor outputs with caution; use a divider or level shifter where needed. |
| A motor driver sits between Pico and motors | The Pico sends control signals; the driver switches the higher motor current. |
| Pico W includes wireless networking | Useful for Wi-Fi projects; the original Pico does not have built-in Wi-Fi. |
| MicroPython is a friendly first language | You can edit and run small programs quickly using Thony’s interactive shell. |
| A basic rover is an excellent first build | It teaches wiring, coding, mechanics, power, and debugging in one wonderfully stubborn little package. |
The RP2040 has a dual-core Arm Cortex-M0+ processor running up to 133 MHz, according to the Raspberry Pico documentation. That’s plenty for common beginner jobs: blinking an LED, reading a line sensor, controlling DC motors, and reacting to obstacles. It’s not a tiny desktop computer, though. Heavy video processing and large machine-learning models are better suited to more capable hardware.
Our first rule at Robotic Coding™: build and test one subsystem at a time. First make the Pico talk to your computer. Then test one motor. Then add a sensor. A robot assembled in one heroic, midnight wiring session often becomes an expensive sculpture.
✅ Good first project: a two-wheel-drive rover that avoids obstacles.
❌ Avoid: connecting a motor or a 5 V sensor output directly to a Pico GPIO pin.
💡 Worth remembering: motor power and logic power may be separate, but their grounds usually need to be connected together.
🤖 What Is Pico Robotics?
Pico robotics means using a Raspberry Pico or Pico W as the controller in a robot. The Pico reads information from sensors, runs your program, and sends control signals to components such as motor drivers, servos, LEDs, and displays.
Tom’s Hardware describes robot building as combining two disciplines: making the physical machine and programming it to respond to inputs. That’s a useful way to think about the whole project: mechanics provide movement, electronics provide connections, and code provides decisions. See its simple Raspberry Pico robot tutorial for another beginner build perspective.
The Pico is a microcontroller board, not a Raspberry Pi computer running Raspberry Pi OS. It starts quickly and runs embedded code directly, making it well suited to repeatable control tasks. The tradeoff is that it has much less memory and computing capacity than a full single-board computer.
| Part of the robot | What it does | Beginner example |
|---|---|---|
| Controller | Runs your robot program | Raspberry Pico |
| Input | Detects the environment or user commands | Ultrasonic distance sensor |
| Logic | Decides what to do with the inputs | “If the obstacle is close, stop and turn” |
| Driver | Handles electrical power for motors | TB6612FNG dual motor driver |
| Output | Creates movement or feedback | DC motors, wheels, LED, buzer |
| Power | Supplies energy to controller and hardware | USB supply or suitable battery pack |
For related hands-on topics, browse our guides to coding languages and robotic sensors.
How the Raspberry Pico Fits Into a Robot
Think of the Pico as the decision-making controller, not the robot’s muscle. Its GPIO pins send low-voltage signals. A motor driver receives those signals and switches motor power on and off, often changing direction and speed as requested.
A typical loop looks like this:
- Read a sensor.
- Interpret the reading in code.
- Choose an action.
- Send control signals to the motor driver.
- Repeat.
That cycle can happen many times per second. It is the same basic pattern used in everything from a simple touch-reactive rover to more advanced automation: sense, decide, act.
The Pico’s RP2040 also includes programmable I/O (PIO), a feature for custom, precisely timed input/output tasks. You likely won’t need PIO in your first rover, but it offers room to grow when ordinary software timing becomes a bottleneck. The RP2040 datasheet documents the processor and its features.
Raspberry Pico vs. Pico W: Which Should You Choose?
Choose the standard Pico for a wired or autonomous robot that does not need networking. Choose the Pico W when you want built-in Wi-Fi for a browser-based controller, telemetry, or an Internet of Things project. Check the current Pico-series documentation before buying, since board features and wireless support vary by model and revision.
| Feature | Raspberry Pico | Raspberry Pico W |
|---|---|---|
| Core use | Standalone embedded control | Embedded control plus wireless projects |
| Built-in Wi-Fi | No | Yes |
| Good first projects | Line follower, obstacle rover, servo control | Wi-Fi remote control, web dashboard, networked sensors |
| Extra complexity | Lower | Network setup, connection handling, security |
| Our recommendation | Best if you want a simple first build | Best if wireless control is a project requirement |
A Wi-Fi board does not automatically make a robot easier. Wireless networking adds useful features but also adds setup and debugging. If your first goal is simply “make it roll forward,” keep it wired until the robot drives reliably.
MicroPython, CircuitPython, and C/C++ at a Glance
For most beginners, MicroPython is the easiest starting point: readable code, quick experiments, and good support for the Pico. CircuitPython is also beginner-friendly, particularly if you use Adafruit hardware and its library ecosystem. C/C++ provides more control and performance but has a steper setup and learning curve.
| Language or environment | Best for | Considerations |
|---|---|---|
| MicroPython | First programs, GPIO, PWM, sensors, quick iteration | Broad Pico learning resources; some libraries differ from desktop Python |
| CircuitPython | Rapid protyping with supported peripherals | Friendly workflows and a substantial Adafruit library collection |
| C/C++ Pico SDK | Tighter performance and lower-level hardware control | More setup and programming concepts to learn |
The MicroPython documentation provides a quick reference for the RP2 family. For CircuitPython, see Adafruit’s Raspberry Pico guide. Our coding languages section has more background if you’re weighing your first language.
📜 The Evolution of Raspberry Pico Robotics
The Raspberry Pico brought the RP2040 microcontroller to hobbyists and educators in a compact board designed for embedded projects. It made it easier to explore physical computing without needing a full Linux computer attached to every robot. Raspberry Pi’s official Pico documentation is the best source for board specifications and setup details.
A basic robot remains a great way to learn because the core ideas haven’t changed: measure something, process the reading, and control an output. In Tom’s Hardware’s touch-driven robot project, the robot responds to physical input using a Pico and a motor-driver board. Our obstacle-avoiding version uses distance readings instead. Different sensors, same fundamental loop.
Pico robotics has also grown beyond simple motor experiments. Hobbyists can now combine a Pico with wireless control, displays, inertial sensors, and small machine-learning experiments. Still, there’s a practical limit: the Pico’s strengths are real-time control and embedded input/output, not demanding image or video processing.
🧭 Plan Your First Pico Robot
Before ordering parts, decide what you want the robot to do. “Move around and don’t hit things” is a fine project brief; “autonomously map a building while recognizing every object” is how a beginner build turns into a semester-long research project.
Write down three things:
- The behavior: follow a line, avoid obstacles, respond to a remote command, or move on touch.
- The environment: tabletop, classroom floor, workshop bench, or outdoor path.
- The learning goal: Python basics, motor control, sensor reading, wireless communication, or mechanical design.
A good project has an obvious way to test success. For example, your line-following robot either stays over the track for a lap or it doesn’t. Clear tests make debugging much less mysterious.
Choose a Beginner-Friendly Robot Project
Here are four solid first builds. They each teach different skills, so “best” depends on what you want to learn.
| Project | Typical inputs | Main lessons | Difficulty |
|---|---|---|---|
| Touch-reactive rover | Bumper switches | Digital inputs, motor direction | Beginner |
| Obstacle-avoiding rover | Ultrasonic distance sensor | Timing, sensor reads, decision logic | Beginner |
| Line-following robot | IR reflectance sensors | Sensor calibration, steering, PWM | Beginner to intermediate |
| Wi-Fi-controlled rover | Pico W and web interface | Wireless networking, commands, safety | Intermediate |
Our usual recommendation is the obstacle rover because it introduces both movement and sensing without requiring a complicated mechanical design. If you want the fastest route to visible progress, a touch-reactive robot can be simpler: press a bumper, make the robot stop or reverse. Tom’s Hardware’s touch-based Pico robot build is a useful alternative.
Set a Realistic Scope and Build Budget
Start with a small chassis, two DC gear motors, a motor driver, a Pico, and one sensor. Add features only after the basic robot moves predictably.
To control complexity, divide the project into milestones:
- Pico connects to Thony.
- Pico runs a test program.
- One motor turns in both directions.
- Both motors move the robot forward.
- A sensor changes the robot’s behavior.
- The robot completes a repeatable test.
No prices here, because parts and availability change. Instead, compare kits by the quality of their documentation, motor-driver compatibility, included battery holder, and whether headers are already soldered. Those details affect your first build far more than a long list of shiny accessories.
🔧 Essential Pico Robotics Supplies and Tools
A basic rover needs a controller, a chassis, motors, a motor driver, a power source, wires, and at least one sensor. You may also need a soldering iron, depending on whether the board and kit come with headers already attached.
| Item | Why you need it | Selection tip |
|---|---|---|
| Raspberry Pico or Pico W | Runs the robot program | Select Pico W if wireless control is a planned feature |
| Two DC gear motors and wheels | Move the robot | Match motor voltage and current to the driver and battery |
| Dual motor driver | Controls motor direction and speed | Check the board’s supported motor voltage and current |
| Chassis and caster | Holds parts and supports motion | Leave room for battery, sensor, and cable routing |
| Battery pack | Powers the robot away from USB | Match voltage to the motors and driver specifications |
| Sensor | Provides input about the environment | Begin with one distance or line sensor |
| Jumper wires and fasteners | Connect and assemble components | Label wires or use consistent colors |
| USB data cable | Programs and powers the Pico during development | A charge-only cable will not provide data communication |
Microcontroller Boards, Cables, and Breadboards
A Raspberry Pico with pre-soldered headers is easier to use on a breadboard than a bare board. If you choose a Pico without headers, you’ll need to solder them or use another compatible connection method. The Raspberry Pico product documentation identifies board features and setup resources.
Use a known-good USB data cable. Some cables charge a device but do not carry data, making a perfectly healthy Pico appear mysteriously invisible to your computer. A small breadboard can help with early sensor experiments, though soldered connections or a robot-specific expansion board are more reliable once the chassis starts rattling.
Motors, Wheels, Chassis, and Mechanical Parts
A two-wheel-drive chassis with two gear motors and a caster is a practical first platform. Gear motors trade speed for torque, which is usually helpful when a small robot carries a battery and sensor.
Before tightening every screw:
- Check that both motors are mounted in the same orientation.
- Turn each wheel by hand and look for rubbing.
- Confirm the caster can swivel freely.
- Make sure the sensor points toward the robot’s travel path.
- Leave a way to reach the USB port and power switch.
Motor Drivers, Batteries, and Power Supplies
The motor driver must match your motors’ voltage and current needs. The L298N is common and easy to find, but it tends to waste more power as heat than newer MOSFET-based boards. The TB6612FNG and DRV883 are popular alternatives for small DC motors; always compare their documentation to the motor’s stall current, not just its normal running current.
For a beginner build, the Kitronik Pico Motor Driver is another option; see Kitronik’s Pico Motor Driver documentation. Board designs differ, so never assume that instructions for one driver apply exactly to another.
Sensors for Obstacle Avoidance and Line Following
Common beginner sensors include:
- HC-SR04 ultrasonic sensor: estimates distance using sound; check its output voltage before connecting it to Pico GPIO.
- IR reflectance sensor or array: distinguishes light and dark surfaces for line following.
- Bumper switch: provides a simple digital signal when the robot makes contact.
- MPU6050 IMU: measures acceleration and angular motion; useful for orientation experiments.
- LDR or light sensor: supports light-seking or brightness detection.
Explore more sensor topics in our robotic sensors category. For every breakout or module, check its own datasheet or official guide: two components with similar names may have different pinouts and voltage requirements.
Hand Tools and Safety Gear
Useful basics include a small screwdriver set, wire cutters, wire strippers, a multimeter, and safety glasses. A soldering iron is useful for durable wiring, but beginners can often start with pre-soldered Pico headers and screw-terminal motor boards.
A multimeter is not just for experts. Use it to check battery polarity, supply voltage, and continuity before powering the circuit. Disconnect the battery before changing wiring. A reversed connection or stray wire can turn a debugging session into a component replacement session.
🛠️ Step 1: Set Up Your Raspberry Pico for Robotics
We begin at the desk, not on the floor. Get the Pico recognized by your computer, install firmware, and run a small test before connecting motors or a battery.
Install Thony and Connect Your Pico
Thony is a beginner-friendly Python IDE with an interactive shell, called the REPL. Download it for your operating system, then connect the Pico with a USB data cable.
For the original Pico, you can use the BOTSEL procedure to expose the board as a USB drive for firmware installation. Raspberry Pi explains the board-specific steps in its getting-started documentation.
The first embedded-programing milestone often feels anticlimactic: an LED blinks, and that’s it. But you’ve just sent code from a computer to a microcontroller and controlled a physical output. That same pattern will eventually control a motor driver.
Flash MicroPython or CircuitPython Firmware
For MicroPython on the Pico:
- Download the correct UF2 firmware from the official MicroPython downloads page. Check the page for the appropriate board variant.
- Unplug the Pico.
- Hold BOOTSEL while plugging it into your computer.
- Release BOTSEL when the board appears as a USB storage device.
- Copy the downloaded UF2 file onto the Pico drive.
- Wait for the board to reboot.
- In Thony, select the MicroPython interpreter for the Pico.
The exact menus may vary by Thony version. If you’d rather use CircuitPython, follow Adafruit’s Pico setup guide and use the firmware and libraries recommended there.
Run a First Test Program
Try this MicroPython test in Thony’s editor:
from machine import Pin
from time import sleep

led = Pin("LED", Pin.OUT)

while True:
 led.toggle()
 sleep(0.5)
``

On a board or firmware version that does not recognize `"LED"`, consult the relevant board documentation for its onboard LED pin. The original Pico’s LED is commonly addressed through GPIO 25; Pico W LED handling differs, so copying a pin number blindly can cause confusion. Raspberry Pi documents these details in its [Pico-series documentation](https://www.raspberrypi.com/documentation/microcontrollers/pico-series.html).

Save your program to the Pico only after you’re confident it behaves as expected. For now, the goal is simple: establish a reliable editor-to-board workflow before adding moving parts.

## ⚙️ Step 2: Learn Motor Control and Choose a Driver

A Pico GPIO pin is designed to signal, not to deliver the current a motor needs. Connect motors through a suitable driver board. The driver takes control signals from the Pico and supplies motor current from the motor power source.

**Never connect a DC motor directly to a Pico GPIO pin.** The [Pico documentation](https://www.raspberrypi.com/documentation/microcontrollers/pico-series.html) provides electrical details for the board; motor-driver manufacturers provide the current and voltage limits for their individual boards.

### How DC Motors, Servos, and Steppers Differ

| Motor type | Typical robot job | Control approach |
|---|---|---|
| DC gear motor | Wheels and simple movement | Driver controls direction; PWM adjusts speed |
| Servo | Steering, grippers, pan-and-tilt mounts | PWM-style control signal sets position |
| Steper motor | Repeatable, incremental rotation | Driver sequences coils; more wiring and control |
| Continuous-rotation servo | Simple small rover movement | Control pulse sets approximate speed and direction |

For a two-wheel rover, **DC gear motors are usually the straightforward choice**. Servos are excellent for sensor scanning or a small gripper. Steppers are useful for more controlled movement but may be unnecessary for a first mobile robot.

### Using an L298N Motor Driver Board

The L298N is widely used in beginner examples, but its exact wiring and regulator setup vary by board. Use the manufacturer or board-specific documentation rather than assuming every module has identical jumpers.

A typical L298N board provides:

- Separate motor output terminals for two DC motors.
- Direction inputs for each motor channel.
- Enable inputs that may accept PWM speed-control signals.
- A motor-power input and ground terminal.
- On some modules, a regulator and jumpers whose behavior depends on board design.

If you use an L298N, check the motor supply and logic requirements, remove or configure enable jumpers only as the board manual specifies, and monitor for heat. **Do not assume the board’s regulator is a safe Pico supply.** Verify its output voltage and the Pico’s permitted power input with a multimeter and the relevant documentation.

### Alternatives to the L298N: TB6612FNG and DRV883

For small, low-voltage robots, modern MOSFET-based drivers can be more efficient than the L298N. That means less voltage lost in the driver and potentially less heat, provided the board is correctly sized for the motors.

| Driver | Potential advantage | Check before choosing |
|---|---|---|
| L298N | Common examples and screw terminals | Heat, voltage drop, module regulator configuration |
| TB6612FNG | Compact and often efficient for small motors | Continuous and peak current limits, voltage range |
| DRV883 | Compact dual motor control for suitable low-voltage motors | Board-specific current capacity and thermal limits |
| Kitronik Pico Motor Driver | Designed for Pico projects | Supported motors, connectors, and power requirements |

The board name alone is not enough. Compare **motor stall current** with the driver’s rated current and thermal conditions. A motor can briefly draw much more current when starting or stalled than it does while spinning freely. Review the relevant [Toshiba TB6612FNG datasheet](https://toshiba.semicon-storage.com/info/docget.jsp?did=1060&prodName=TB6612FNG) or [Texas Instruments DRV883 documentation](https://www.ti.com/product/DRV8833) before selecting a driver.

### Control Speed with PWM and Direction Pins

Direction pins tell the driver which way a motor should turn. A PWM signal on an enable pin can regulate the average power delivered to the motor. In MicroPython, PWM duty is commonly represented as a value from 0 to 65,535 on RP2 boards.

Example setup for one PWM pin:

```python
from machine import Pin, PWM

motor_pwm = PWM(Pin(8))
motor_pwm.freq(100)
motor_pwm.duty_u16(32768) # Approximately 50% duty cycle
``

This only configures a PWM signal. It does **not** make a motor safe to connect directly to GPIO. The PWM output should go to a compatible motor-driver input, with the motor connected to the driver’s output terminals.

Start at low duty, raise it gradually, and test with the wheels lifted off the ground. The first time both wheels spin in the same direction, you’ll feel like a robotics wizard. The first time one spins backward, you’ll learn that motor wiring has a sense of humor.

## 🧩 Step 3: Design and Build the Robot Chassis

A robot can have perfect code and still drive terribly if a wheel rubs against the chassis or the battery sits too high. Mechanical setup is part of robotics, not an optional decorative phase.

### Choose a Two-Wheel or Four-Wheel Drive Layout

A two-wheel-drive chassis with one caster is usually the simplest to build and control. Four-wheel drive can offer traction, but adds extra alignment and motor-control questions.

| Layout | Benefits | Tradeoffs |
|---|---|---|
| Two drive wheels plus caster | Simple differential steering; fewer motors | Caster alignment and weight balance matter |
| Four-wheel drive | More traction on some surfaces | More motor wiring and potential speed mismatch |
| Tracked chassis | Better grip on loose surfaces | Higher mechanical friction and more current demand |
| Small servo-stered car | Familiar steering behavior | More complex chassis and turning geometry |

For an indoor beginner rover, start with **two drive wheels and a caster**. You can add complexity later when the basic machine turns reliably.

### Mount Motors, Wheels, and the Caster

1. Lay out the chassis and identify left, right, front, and rear.
2. Mount both motors symetrically.
3. Fit the wheels and confirm they turn freely.
4. Attach the caster so it can swivel without catching.
5. Lift the robot and spin each wheel by hand.
6. Check that wires cannot tangle with the wheels.

If your robot repeatedly vers to one side, the culprit may not be code. Motor tolerances, wheel friction, battery placement, or misaligned brackets can all create uneven motion.

### Position the Pico, Sensors, and Battery

Place the battery low and near the chassis center to improve stability. Mount the Pico on insulated standoffs or a secure holder, especially if the chassis is metal. Position the distance sensor where it can “see” the area ahead without being blocked by a wheel, bumper, or dangling wire.

Leave access to the USB port, reset button, battery connector, and power switch. A robot that needs to be disassembled every time you want to edit code is a robot that will teach you to procrastinate.

## 🔌 Step 4: Wire the Pico Robot Electronics Safely

Disconnect power while you wire. Then check every connection against the pinout for your exact motor-driver board and sensor.

### Connect the Pico to a Motor Driver

This is a **conceptual example**, not a universal wiring diagram. Use it only if it matches your driver board’s manual and your chosen Pico pins.

| Pico or battery connection | Example driver connection |
|---|---|
| Pico GPIO 10 | Motor driver direction input 1 |
| Pico GPIO 11 | Motor driver direction input 2 |
| Pico GPIO 12 | Motor driver direction input 3 |
| Pico GPIO 13 | Motor driver direction input 4 |
| Pico PWM GPIO 8 | Motor driver enable or PWM input A |
| Pico PWM GPIO 9 | Motor driver enable or PWM input B |
| Pico GND | Driver GND |
| Motor battery positive | Driver motor-power input |
| Motor battery negative | Driver GND |
| Left motor leads | Driver motor output A |
| Right motor leads | Driver motor output B |

**The Pico and motor driver need a common ground** for their control signals to have a shared electrical reference. That does not mean you should connect battery voltage to a GPIO pin. Keep motor power on the driver’s motor-power terminals.

A particularly important correction to some beginner wiring diagrams: **never treat a motor driver’s 5 V terminal as automatically safe for powering Pico VBUS or VSYS**. Board layouts, regulator jumpers, and Pico power inputs differ. Follow the official [Pico power documentation](https://www.raspberrypi.com/documentation/microcontrollers/pico-series.html) and your driver’s manual; verify voltages before connecting.

### Wire Ultrasonic, Infrared, and Line Sensors

For each sensor, confirm:

- Supply-voltage range.
- Signal-voltage level.
- Pin labels and pinout.
- Whether the output is analog, digital, I²C, or another interface.

Some HC-SR04 modules use 5 V and may output a 5 V echo signal. Pico GPIO uses 3.3 V logic and is **not 5 V tolerant**. Use a voltage divider or logic-level shifter on any 5 V output before it reaches the Pico. Alternatively, choose a distance sensor with a 3.3 V-compatible interface.

For analog sensors, the Pico has ADC-capable pins, but not every GPIO is analog input. Check Raspberry Pi’s [RP2040 documentation](https://datasheets.raspberrypi.com/rp2040/rp2040-datasheet.pdf) and the sensor’s datasheet before assigning pins.

### Plan Power, Ground, and Voltage Levels

During programming, USB can power the Pico by itself. A mobile robot also needs a suitable source for its motors. Depending on the driver and project, you may use separate motor and logic supplies, or a carefully designed shared battery system with the correct regulation.

| Circuit | What to verify |
|---|---|
| Pico logic supply | Correct voltage at the supported Pico input |
| Motor supply | Within the driver and motor operating ranges |
| Shared ground | Pico GND and driver GND connected as required |
| Sensor supply | Matches sensor documentation |
| Sensor output | Does not exceed Pico GPIO voltage limits |
| Battery connection | Correct polarity and secure connector |

A 2-cell LiPo battery is not a casual “plug it in and see” choice. It requires a compatible charger, careful handling, and a circuit designed for its voltage range. If this is your first robot, a suitable protected battery holder or regulated supply may feel less exciting, but it can make the build much safer.

### Check Your Wiring Before Switching On

Use a deliberate preflight checklist:

- Battery is disconnected.
- No bare wires can touch the chassis or each other.
- Motor outputs connect only to the driver’s motor terminals.
- Pico GPIO connects only to driver logic inputs or compatible sensor signals.
- Common ground is present where required.
- Polarity matches the board markings.
- Sensor outputs are safe for 3.3 V GPIO.
- Motor wheels are raised for the first test.

✅ **Power up only after checking the driver and sensor documentation.**
❌ **Do not use “it fits the connector” as proof of electrical compatibility.**

## 💾 Step 5: Program Your Pico Robot

The first program should do one thing well: move the motors predictably. Add obstacle logic only after direction, speed, and stopping behavior are understood.

### Write a MicroPython Motor-Control Program

Here’s a simple example of motor direction control for a driver with four direction inputs and two PWM enable inputs. Adapt the pins to your actual wiring and driver board.

```python
from machine import Pin, PWM
from time import sleep

left_in1 = Pin(10, Pin.OUT)
left_in2 = Pin(11, Pin.OUT)
right_in1 = Pin(12, Pin.OUT)
right_in2 = Pin(13, Pin.OUT)

left_pwm = PWM(Pin(8))
right_pwm = PWM(Pin(9))

left_pwm.freq(100)
right_pwm.freq(100)

def set_speed(percent):
 percent = max(0, min(100, percent))
 duty = int(percent * 65535 / 100)
 left_pwm.duty_u16(duty)
 right_pwm.duty_u16(duty)

def stop():
 set_speed(0)
 left_in1.value(0)
 left_in2.value(0)
 right_in1.value(0)
 right_in2.value(0)

def forward(speed=40):
 left_in1.value(1)
 left_in2.value(0)
 right_in1.value(1)
 right_in2.value(0)
 set_speed(speed)

try:
 forward(40)
 sleep(1)
finally:
 stop()
``

Some drivers brake when both input pins are high; others have different behavior. Read the board’s truth table before adding reverse, braking, or coast modes. Test the program with the robot lifted so it cannot dart off a table.

### Read Sensors and Add Obstacle Avoidance

For an ultrasonic sensor, the general measurement idea is to send a trigger pulse, time the echo, and estimate distance from the sound’s travel time. The HC-SR04 documentation and your particular module’s notes should guide the exact timing and voltage protection.

A beginner decision rule could be:

```text
If distance is greater than the safety threshold:
 drive forward
Otherwise:
 stop
 reverse briefly
 turn
 resume
``

A threshold around 20 cm is a common demonstration setting, not a universal safety guarantee. Sensor readings vary with target shape, angle, surface, and environment. For safer behavior, take multiple readings, reject timeouts, and slow down as the obstacle gets closer.

### Try CircuitPython Libraries and C/C++

CircuitPython can be convenient when Adafruit provides a library for your sensor or display. MicroPython is a strong general-purpose choice for straightforward Pico control. If performance or low-level hardware access becomes a constraint, consider the [Pico C/C++ SDK](https://github.com/raspberrypi/pico-sdk).

This is a progression, not a competition. Pick a tool that lets you learn the robot’s behavior instead of spending the whole evening configuring a compiler. For broader programming discussions, visit our [coding languages category](https://roboticcoding.com/category/coding-languages/).

### Organize Code with Functions and State Machines

Functions keep repeated actions understandable: `forward()`, `reverse()`, `turn_left()`, and `stop()` are easier to debug than scattered pin writes.

For a growing project, represent behavior as states:

- `DRIVE_FORWARD`
- `OBSTACLE_DETECTED`
- `BACK_UP`
- `TURN`
- `RECOVER`

A state machine makes the robot’s choices easier to test and prevents a long sequence of sleeps from becoming the entire control strategy. It also gives you a clear answer to the question, “What is the robot trying to do right now?”

## 🚀 Step 6: Install Drivers and Test Your Robotics Setup

A Pico generally appears as a USB device when firmware and cable setup are correct; you usually do not need a separate “motor driver” installed on your computer for an ordinary driver board. You do need the correct firmware, IDE configuration, and sometimes an operating-system USB or serial permission setup.

### Check USB, Serial, and Thony Connections

If Thony cannot connect:

1. Try a known data-capable USB cable.
2. Disconnect and reconnect the board.
3. Confirm the correct interpreter and port in Thony.
4. Reinstall or reflash the correct firmware if necessary.
5. Check operating-system permissions and device selection.
6. Close another application that may already be using the serial connection.

The official [Raspberry Pi MicroPython setup instructions](https://www.raspberrypi.com/documentation/microcontrollers/micropython.html) are the best starting point for board-specific setup.

### Test Motors and Sensors One at a Time

Keep the wheels raised for the first motor test.

1. Confirm the motor battery is connected to the driver correctly.
2. Run one motor at low speed.
3. Stop it.
4. Test the second motor.
5. Check forward and reverse direction.
6. Read the sensor separately and print its values.
7. Combine the systems only after each works on its own.

If a wheel spins in the wrong direction, swap the motor leads at the driver output or reverse the direction logic in software. If your robot circles, test whether one motor is wired backward, mechanically obstructed, or simply slower than the other.

### Calibrate Movement and Sensor Readings

The same PWM duty does not guarantee identical wheel speed. Gear motors vary, battery voltage changes, and friction differs. Start with simple calibration:

- Run the robot on a flat surface for a fixed time.
- Measure how far it travels and whether it vers.
- Adjust left and right PWM values.
- Repeat with a fresh battery and the intended floor surface.

For line sensors, record readings over the line and over the background, then choose a threshold based on your actual track. Bright sunlight and surface finish can affect infrared sensing, so test in the room where the robot will operate.

## 🎉 Step 7: Bring Your Pico Robot to Life with First Projects

The first reliable movement is the moment a pile of parts becomes a robot. Begin in an open, level area, away from stairs, pets, glassware, and the world’s most tempting table edge.

### Build a Remote-Controled Pico Robot

A Pico W can host a simple web interface or connect to a network so you can send movement commands. Start with a basic “forward,” “back,” “left,” “right,” and “stop” control. Make **stop the default behavior** if the connection drops.

Wireless projects add security and reliability questions. Keep the robot on a trusted local network during experiments, avoid exposing control interfaces to the public Internet, and design a clear physical power switch. Raspberry Pi’s [Pico W documentation](https://www.raspberrypi.com/documentation/microcontrollers/pico-series.html) is the place to confirm wireless capabilities for your board.

### Make a Line-Following Robot

A line follower uses reflectance sensors to detect contrast between a track and its background. A three-sensor arrangement can indicate whether the line is left, centered, or right.

A basic steering strategy:

- Line centered: drive both motors at similar speed.
- Line appears left: slow one motor or speed the other to steer left.
- Line appears right: steer right.
- No line detected: stop or search cautiously.

Set the sensor height and threshold carefully. Some inexpensive IR modules have a small adjustment potentiometer; others provide raw analog readings that you can calibrate in code. Once simple steering works, proportional or PID-style control can make turns smoother.

### Create an Ultrasonic Obstacle-Avoiding Robot

Mount the sensor facing forward and use a safe voltage interface. A basic behavior loop can stop, reverse, turn, and try again when an obstacle is within a chosen distance.

To improve it:

1. Take a few readings rather than trusting a single measurement.
2. Handle missing or implausible readings explicitly.
3. Reduce speed as the obstacle gets closer.
4. Test with different surfaces and obstacle angles.
5. Use a bumper switch as a backup if contact would be damaging.

A distance sensor is not a magic force field. Soft, angled, narrow, or oddly shaped objects can produce inconsistent readings. Give the robot room and supervise early tests.

### Add Wi-Fi Control with a Raspberry Pico W

With the Pico W, you can experiment with networked control, status pages, and sensor telemetry. Begin with a local connection and a small command set. Do not add video streaming expectations: a Pico is a microcontroller, and its resources are limited compared with a Linux board.

For projects involving advanced perception, you can explore [artificial intelligence](https://roboticcoding.com/category/artificial-intelligence/) and [robotic simulations](https://roboticcoding.com/category/robotic-simulations/) as learning pathways. A useful progression is to prototype the decision logic on a computer, then deploy a small version to the robot.

## 🔋 Powering and Maintaining Your Pico Robot

Power problems often masquerade as software bugs. A robot that resets when a motor starts may have voltage sag, noise, a weak battery, or a wiring fault—not a haunted `while` loop.

### Choose Batteries and Estimate Runtime

Choose a battery compatible with the motor driver, motors, regulator, and Pico power path. Review the voltage range and current ratings for **every** board in the chain. Do not infer battery compatibility from a kit photo.

A rough runtime estimate is:

```text
Estimated runtime (hours) ≈ battery capacity (Ah) ÷ average current draw (A)
``

This is only an estimate. Actual runtime changes with motor load, acceleration, surface friction, battery age, and the electronics’ consumption. Measure real current if runtime matters.

### Avoid Brownouts, Overheating, and Electrical Damage

- Keep motor current within the driver’s ratings.
- Do not run a stalled motor for long; stall current can be high.
- Use a supply suited to the motor driver and Pico.
- Keep motor power wiring away from delicate sensor wiring where practical.
- Check driver temperature during early tests.
- Use correct charging equipment for rechargeable batteries.
- Add electrical noise suppression only according to sound design practice and component documentation.

If the Pico resets as the motors start, stop and inspect the power design rather than increasing code delays. Separate supplies or suitable regulation may help, but the grounds still generally need a shared reference for control signals.

### Inspect, Store, and Maintain Your Robot

Before a test run, check that screws are tight, wheels turn freely, battery connectors are secure, and wires cannot snag. After a run, disconnect the battery if the robot will be stored.

For LiPo batteries, follow the manufacturer’s storage and charging guidance. Do not use a swollen or damaged battery. Treat small batteries with respect: they are compact power sources, not tiny pillows.

## 🔍 Troubleshoot Common Pico Robotics Problems

Debuging is a core robotics skill. Change one thing at a time, write down what happened, and resist the urge to rewire the entire robot while it is still powered.

| Symptom | Likely causes | First checks |
|---|---|---|
| Pico not detected | Charge-only cable, wrong port, firmware/setup issue | Change cable, check interpreter, follow official setup |
| Motors do not move | Missing motor power, wrong wiring, disabled channel | Check battery and driver manual |
| Robot circles | Reversed motor, speed mismatch, wheel friction | Test wheels separately and calibrate |
| Pico resets on acceleration | Voltage sag, motor noise, poor power layout | Inspect supply, wiring, driver limits |
| Sensor readings jump | Voltage mismatch, loose wires, motor interference | Check levels, grounds, routing, repeat readings |
| Program stops unexpectedly | Runtime exception, pin conflict, stalled code | Read Thony Shell and test smaller program |

### The Pico Is Not Recognized by Your Computer

First suspect the USB cable. A charge-only cable is a classic culprit. Then try another USB port, check the device selection in Thony, and confirm that the board is in the expected firmware mode. Use Raspberry Pi’s [MicroPython setup guide](https://www.raspberrypi.com/documentation/microcontrollers/micropython.html) for the correct recovery procedure.

### Motors Do Not Turn or Run in the Wrong Direction

Check the motor battery and the driver’s enable configuration first. Then verify that the direction pins in your code match the wires on the driver. Swap a motor’s two output leads or reverse its direction logic if needed.

If the driver gets hot or the motor stalls, disconnect power. A driver that is undersized for the motor may be overheating or entering protection.

### The Robot Resets When the Motors Start

Motor startup can pull the supply voltage down or introduce electrical noise. Check:

- Battery charge and current capability.
- Motor-driver current rating.
- Power wiring and connector condition.
- Whether Pico and motor supplies are arranged according to documentation.
- Whether grounds are common where required.

A reset that happens exactly when a motor starts is a strong clue that the issue is electrical, not that MicroPython has suddenly developed stage fright.

### Sensors Give Unreliable Readings

Confirm sensor voltage and pinout. Keep sensor wires secure and, where possible, away from high-current motor wiring. Take several readings and reject timeouts or implausible values. For ultrasonic sensors, target shape and angle matter; for infrared line sensors, floor color and ambient light matter.

### Fix MicroPython Errors and Pin Conflicts

Read the Thony Shell traceback from the bottom upward. Common causes include misspeled pin names, using a pin for two incompatible functions, missing libraries, and calling the wrong method for a PWM or sensor object.

When a program fails:

1. Save a copy.
2. Remove new features until the previous working version returns.
3. Test each hardware input or output alone.
4. Add one change back at a time.
5. Print sensor values and state changes during debugging.

## 💡 Advanced Raspberry Pico Robotics Tips

After the robot reliably moves, you can improve precision and responsiveness. Add one new concept at a time; “advanced” is often just “beginer, but with more useful measurements.”

### Use Interrupts, Encoders, and Closed-Loop Control

Wheel encoders report rotation, allowing the robot to estimate how far each wheel has moved. That’s more reliable than assuming a fixed delay means a fixed distance. Use feedback to correct unequal motor speeds or improve turns.

GPIO interrupts can notify code when an event occurs, such as an encoder edge or button press. Use them carefully: interrupt handlers should be short and predictable. MicroPython’s [RP2 quick reference](https://docs.micropython.org/en/latest/rp2/quickref.html) and the [RP2040 datasheet](https://datasheets.raspberrypi.com/rp2040/rp2040-datasheet.pdf) are useful references.

### Add Bluetooth, Wi-Fi, or Web-Based Controls

Wireless control works well for interactive demos, telemetry, and remote commands. Keep a local physical stop or power switch, and define what happens if packets stop arriving.

The Pico W’s built-in networking is useful for compact projects, but it doesn’t turn the board into a general-purpose computer. For projects that need richer interfaces or substantial vision processing, consider pairing the Pico with a more capable computer rather than forcing every job onto the microcontroller.

### Design a Custom PCB or 3D-Printed Chassis

A custom PCB can replace fragile breadboard connections and simplify repeat builds. A 3D-printed chassis can improve sensor placement and cable management. Before ordering a PCB or printing a final chassis, test the circuit and geometry with temporary parts.

Good design habits include:

- Label connectors and power rails.
- Add mounting holes and cable strain relief.
- Keep motor-current paths distinct from sensitive sensor signals.
- Make battery access and switching easy.
- Document pin assignments in code and on the board.

### Improve Robot Reliability and Code Performance

For more responsive control, reduce unnecessary blocking sleeps and separate sensor sampling from movement decisions. MicroPython’s `asyncio` may help structure tasks, though you should understand the basics before adding concurrency. The RP2040 also offers two cores, but multi-core code brings synchronization and debugging overhead.

Start with measured problems. If the robot responds quickly enough, a complicated architecture may only create new bugs. Reliability is a feature too.

## 🌐 Pico Robotics Communities and Learning Resources

Robotics gets easier when you can compare notes with other builders. When asking for help, include your board model, driver model, wiring diagram, firmware, code snippet, and what you expected versus what happened. “It doesn’t work” is emotionally accurate but electrically unhelpful.

### Find Help in Raspberry Pi and MicroPython Communities

Useful places to learn include:

- [Raspberry Pi documentation](https://www.raspberrypi.com/documentation/microcontrollers/pico-series.html) for official hardware and setup information.
- [Raspberry Pi forums](https://forums.raspberrypi.com/) for community discussion.
- [MicroPython documentation](https://docs.micropython.org/en/latest/) for language and hardware references.
- [Adafruit Learn](https://learn.adafruit.com/) for tutorials and supported CircuitPython hardware.
- [GitHub](https://github.com/) for example projects and source code; check maintenance status and licenses before reuse.

For community projects, distinguish a practical tutorial from an electrical design you should trust. A project can be fun and still contain wiring assumptions that do not match your board.

### Choose a Learning Path for Your Next Project

A sensible progression:

1. Blink an LED and read a button.
2. Read a sensor and display its values.
3. Drive one motor through a driver.
4. Control two motors with direction and PWM.
5. Build an obstacle rover or line follower.
6. Add encoders, wireless control, or more advanced behavior.
7. Explore small machine-learning models only when the basic robot is dependable.

For small embedded machine-learning experiments, investigate [Edge Impulse](https://www.edgeimpulse.com/) and its supported-device documentation. Model size, memory, and processing needs matter: the Pico is not a good fit for heavy image or video inference. Use our [artificial intelligence resources](https://roboticcoding.com/category/artificial-intelligence/) to explore the wider topic.

🏁 The big question from the workbench is now answered: the Pico can absolutely be the brain of a beginner robot, as long as the motors get a proper driver and the wiring respects the board’s 3.3 V limits. The first rover does not need to be clever. It needs to move, sense, and teach you what to try next.